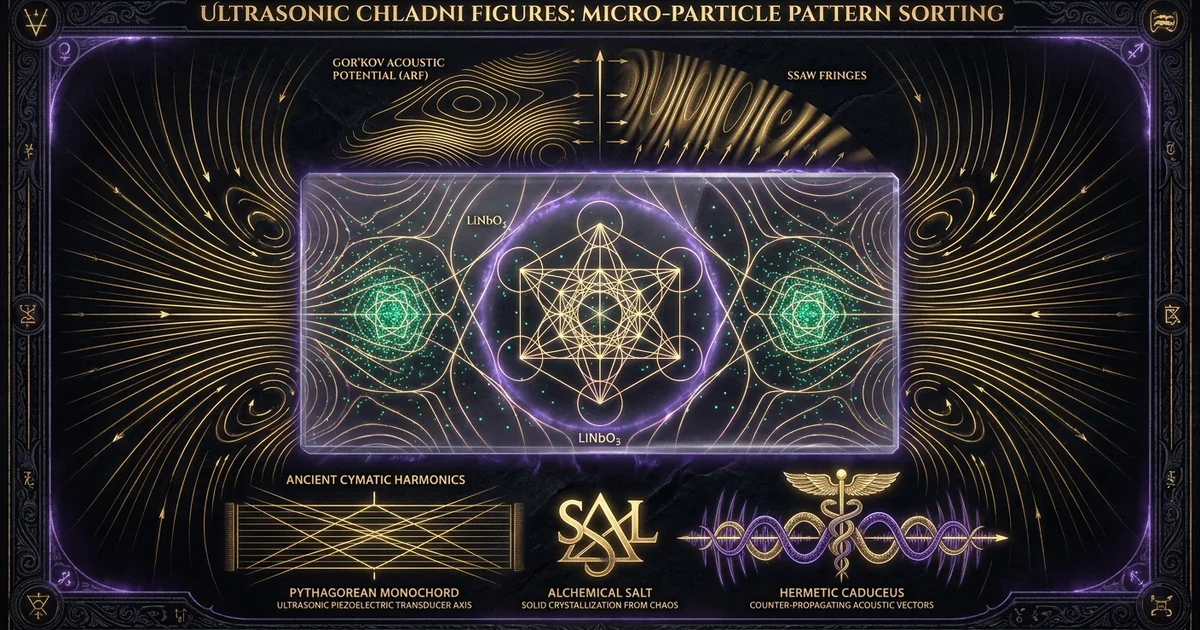
Ultrasonic Chladni Figures: Micro-Particle Pattern Sorting
Executive Summary & Theoretical Thesis: High-Frequency Cymatic Sorting Mechanics
The Paradigm Shift: From Audible Plate Resonance to Megahertz Acoustic Manipulation
The physical visualization of acoustic vibration through particulate clustering on vibrating boundaries—first formalized by Ernst Florens Friedrich Chladni in 1787—has historically occupied the boundary between classical elastodynamics and phenomenological demonstration. In audible-frequency regimes (spanning 100 Hz to 15 kHz), mechanical excitation of macroscopic isotropic plates yields flexural standing waves whose wavelengths measure on the order of centimeters. Particulate matter randomly dispersed upon such surfaces undergoes violent, intermittent collisions with the oscillating boundary, migrating gravitationally and ballistically toward cymatic-modal-nodes where transverse mechanical displacement vanishes.
The transition into the megahertz ultrasonic regime (1 MHz to 50 MHz) fundamentally inverts this mechanical framework. When the operational excitation frequency scales by three to four orders of magnitude, the acoustic wavelength within liquid-loaded elastic substrates and adjacent microfluidic volumes contracts to the micrometer scale ($30,\mu\text{m} \le \lambda \le 1500,\mu\text{m}$). In this spatial domain, continuous mechanical impacts give way to the primary acoustic radiation force, transforming passive macroscopic modal lines into deterministic, high-throughput micro-traps. Ultrasonic Chladni figures micro particle assembly acoustic mechanics no longer depend on gravity or loose particulate bouncing; instead, they operate through coherent momentum transfer from high-frequency acoustic waves to suspended matter, governed by the continuum elastodynamics of the underlying substrate and fluid layer.
This dimensional down-scaling matches the physical dimensions of single biological cells, organelle clusters, and synthetic colloidal nanoparticles. Consequently, megahertz vibration nodal lines cease to be merely diagnostic patterns of structural vibration; they function as active, non-contact, spatial-energy landscapes. By replacing the chaotic inertial kicking of Chladni’s historical sand grains with deterministic wave-matter interactions, microfluidic ultrasonic resonators achieve rapid spatial fractionation. This methodology establishes an empirical, high-throughput paradigm that bridges classical wave geometry with sub-cellular bio-fabrication, providing a rigorous physical alternative to electromagnetic or fluid-shear micro-manipulation.
Macro-Chladni Regime (Hz to kHz)          Ultrasonic Chladni Regime (MHz)
Wavelength: λ ~ 10⁻² to 10⁻¹ m            Wavelength: λ ~ 10⁻⁶ to 10⁻⁴ m
Force: Inertial bouncing / Gravity         Force: Acoustic Radiation Force (-∇U)
Medium: Dry plates in air                  Medium: Liquid-loaded substrates / microfluidics
Particles: Sand / macroscopic grains       Particles: Cells / Colloidal nanoparticles
The Acoustic Radiation Landscape and the Gor’kov Potential
When micro-particles reside within an ultrasonic standing wave field within an inviscid or weakly viscous fluid, the acoustic field generates a time-averaged spatial potential rather than a mere oscillatory displacement. The resulting force driving particulate migration corresponds to the primary acoustic-radiation-force ($\mathbf{F}_{\text{rad}}$). In the long-wavelength Rayleigh limit, where the particulate radius $a$ is significantly smaller than the acoustic wavelength ($a \ll \lambda$ or $k a \ll 1$, where $k = 2\pi/\lambda$ represents the acoustic wavenumber), this force field is mathematically conservative and can be expressed strictly as the negative spatial gradient of an acoustic scalar potential:
$$\mathbf{F}{\text{rad}} = -\nabla U{\text{rad}}$$
This scalar formulation, historically derived by Lev Petrovich Gor’kov in 1962, constructs the energy landscape from the local acoustic field variables: the mean-square acoustic pressure $\langle p^2 \rangle$ and the mean-square acoustic particle velocity $\langle \mathbf{v}^2 \rangle$. The acoustic radiation landscape thus functions as a multi-dimensional harmonic energy well. Suspended micro-matter is dynamically swept along the gradient of $U_{\text{rad}}$ toward stable topological minima dictated by the interference geometry of the standing waves.
These minima coincide precisely with either the pressure nodes (velocity antinodes) or pressure antinodes (velocity nodes) of the modal architecture. As detailed in foundational treatises on acoustic levitation mechanics, the spatial topology of these Gor’kov wells mirrors the underlying elastodynamic mode shapes of the substrate, generating micro-scale ultrasonic Chladni patterns within the liquid suspension.
Deterministic Micro-Scale Sorting via Acoustic Contrast Factors
The directionality and magnitude of the primary acoustic radiation force depend directly on the mechanical mismatch between the suspended particulate and the suspending immersion fluid. This intrinsic material property is parameterized by the acoustic-contrast-factor, designated herein as $\Phi(\tilde{\kappa}, \tilde{\rho})$. The contrast factor dictates whether a specific particulate species experiences an attractive force toward the megahertz vibration nodal lines or is dynamically expelled toward the pressure antinodes.
Because the acoustic contrast factor is an explicit function of both the relative mass density $\tilde{\rho} = \rho_p / \rho_0$ and the relative isentropic compressibility $\tilde{\kappa} = \kappa_p / \kappa_0$ (where the subscript $p$ denotes particulate properties and $0$ denotes ambient fluid properties), ultrasonic Chladni sorting operates on intrinsic physical parameters without requiring exogenous biochemical labels, magnetic tagging, or surface chemical functionalization.
Mammalian cells, bacteria, synthetic polymers (e.g., polystyrene, PMMA), and inorganic metallic colloids all exhibit unique acoustic contrast signatures. In mixtures containing heterogeneous particulate populations, divergent Gor’kov potentials operate simultaneously across the acoustic landscape. Particles with positive contrast factors ($\Phi > 0$) rapidly condense onto the substrate displacement nodes, while particles or lipid droplets exhibiting negative contrast factors ($\Phi < 0$) isolate simultaneously at antinodal regions. This sorting mechanism provides a non-invasive, label-free, and high-throughput alternative to dielectrophoresis and optical tweezers, functioning within physiologically compatible microfluidic environments without thermal or electrical damage to living systems.
The scaling behavior of the primary acoustic radiation force $\mathbf{F}{\text{rad}}$ versus the Stokes drag force $\mathbf{F}{\text{drag}}$ dictates the operational bounds of ultrasonic Chladni manipulation. For a spherical particle of radius $a$ suspended in a medium of dynamic viscosity $\eta$ and sound speed $c_0$, actuated at frequency $f = \omega / (2\pi)$:
- Wavelength Scaling: $\lambda = c_0 / f$. In water ($c_0 \approx 1480,\text{m/s}$), increasing $f$ from $1,\text{kHz}$ to $20,\text{MHz}$ collapses $\lambda$ from $1.48,\text{m}$ down to $74,\mu\text{m}$.
- Gor’kov Acoustic Radiation Force Scaling: $$\mathbf{F}{\text{rad}} \propto a^3 \cdot k \cdot E{\text{ac}} \propto a^3 \cdot f \cdot p_0^2$$ where $E_{\text{ac}} = p_0^2 / (4 \rho_0 c_0^2)$ represents the acoustic energy density and $p_0$ is the acoustic pressure amplitude.
- Stokes Hydrodynamic Drag: $$\mathbf{F}{\text{drag}} = 6 \pi \eta a \mathbf{v}{\text{rel}}$$ where $\mathbf{v}_{\text{rel}}$ is the relative velocity induced by boundary-driven acoustic streaming.
- The Crossover Threshold: Because $\mathbf{F}{\text{rad}} \propto a^3$ and $\mathbf{F}{\text{drag}} \propto a$, a critical radius $a_c$ exists below which viscous drag from micro-scale acoustic streaming vortices dominates over the primary radiation force: $$a_c \sim \sqrt{\frac{3 \Psi \nu}{\omega}}$$ where $\nu = \eta/\rho_0$ is the kinematic viscosity and $\Psi$ is a dimensionless geometry-dependent streaming factor. At $1,\text{MHz}$, $a_c \approx 1.5,\mu\text{m}$; at $40,\text{MHz}$, $a_c$ drops below $200,\text{nm}$, enabling the direct, deterministic manipulation of colloidal nanoparticles.
Historical Lineage & Experimental Precedents: From Chladni Plates to Microfluidic Resonators
Classical Foundations: Ernst Chladni and Faraday’s Boundary Layer Streaming
The experimental lineage of acoustic pattern formation originates with Ernst Florens Friedrich Chladni’s 1787 publication Entdeckungen über die Theorie des Klanges. Chladni swept a violin bow perpendicularly across the edge of sand-strewn, clamped brass and glass plates. By mechanically constraining selected plate coordinates, he excited structural eigenmodes of two-dimensional transverse vibration, forcing the sand grains to evacuate high-acceleration anti-nodal zones and collect along stationary nodal lines where the transverse velocity approached zero. These nodal topologies visualized the two-dimensional solutions to the fourth-order biharmonic plate equation, providing the first systematic mapping of macroscopic modal boundaries.
Historical Trajectory of Cymatic Systems:
[Chladni (1787): Bowed Plates]
       │
       ▼
[Faraday (1831) & Rayleigh (1883): Boundary Streaming Dynamics]
       │
       ▼
[Mid-20th Century: PZT Transduction & Bulk Standing Waves]
       │
       ▼
[Modern Microfluidics: LiNbO3 Surface Acoustic Wave (SAW) Resonators]
However, Chladni’s macroscopic experiments were constrained by environmental and physical boundaries: the mechanics operated in ambient air under continuous gravitational influence, resting on dry friction, and relying entirely on macroscopic particles whose dimensions exceeded hundreds of micrometers. In 1831, Michael Faraday identified an apparent anomaly in Chladni’s framework: when dense sand was replaced with fine particulate matter such as lycopodium powder, the particles gathered not at the nodal lines, but precisely at the antinodes of maximum mechanical vibration.
Faraday correctly deduced that the motion of fine particles was dictated not by ballistic plate collisions, but by hydrodynamic air currents generated adjacent to the vibrating surface—a phenomenon now formalized as acoustic-streaming. Lord Rayleigh subsequently derived the mathematical foundation of this boundary layer phenomenon in 1883, demonstrating that Reynolds stress gradients inside the viscous Stokes boundary layer drive steady recirculating vortex cells. These classical investigations proved that acoustic particulate assembly always balances bulk acoustic forces against viscous hydrodynamic dissipation, a dualism that remains central to modern ultrasonic devices.
“Wenn die Platte auf diese Weise in Schwingung versetzt wird, so sieht man, wie der Sand sich von den schwingenden Theilen weg nach den Ruhelinien hinbewegt… und so die Theilungslinien des Tones auf das Genaueste zeichnet.”
— Ernst F. F. Chladni, Entdeckungen über die Theorie des Klanges (Weidmanns Erben und Reich, Leipzig, 1787).
“The abnormal movement of light powders on vibrating plates, noticed by Chladni, is due to the currents of air which are set up by the motion of the plate… The fine particles, following the air currents, are swept up to the antinodes, whereas heavier particles, governed by inertia, settle at the nodal lines.”
— Lord Rayleigh (John William Strutt), “On the Circulation of Air Observed in Kundt’s Tubes, and on Some Allied Acoustical Problems,” Philosophical Transactions of the Royal Society of London, Vol. 175, 1884, pp. 1–21.
The Solid-State Acoustical Revolution: Piezoelectric Transduction
The classical methodology of bowing or electromechanically shaking metallic diaphragms was limited to low-frequency regimes bounded by mechanical inertia and acoustic damping. The modern transition to ultrasonic manipulation required the development of synthetic ferroelectric and piezoelectric-transduction substrates during the mid-20th century. The discovery of lead zirconate titanate ($\text{Pb}[\text{Zr}x\text{Ti}{1-x}]\text{O}_3$ or PZT) and the later micro-machining of single-crystal lithium niobate ($\text{LiNbO}_3$) transformed elastodynamics by enabling direct electromechanical conversion in the megahertz spectrum.
Applying a high-frequency alternating electric field across a polarized piezoelectric material induces macroscopic mechanical deformation via the inverse piezoelectric effect, characterized by the linear constitutive relations:
$$S_{ij} = s_{ijkl}^E T_{kl} + d_{kij} E_k$$
$$D_i = d_{ikl} T_{kl} + \varepsilon_{ik}^T E_k$$
where $S_{ij}$ is the mechanical strain tensor, $T_{kl}$ is the mechanical stress tensor, $E_k$ is the applied electric field vector, $D_i$ is the electric displacement vector, $s_{ijkl}^E$ is the elastic compliance tensor at constant electric field, $d_{kij}$ is the piezoelectric strain coupling coefficient tensor, and $\varepsilon_{ik}^T$ is the dielectric permittivity tensor at constant mechanical stress.
By fabricating sub-millimeter piezoelectric ceramics coupled directly to silicon, glass, or polymer acoustic microfluidic channels, modern acoustofluidic systems generate standing acoustic wave fields at frequencies exceeding 40 MHz. This solid-state framework eliminates mechanical wear and enables stable, continuous harmonic excitation at micro-scale wavelengths.
Integration of Bulk and Surface Acoustic Waves into Micro-Scale Sorting
Modern microscale acoustofluidics branches into two primary structural implementations: Bulk Acoustic Wave (BAW) resonators and surface-acoustic-wave (SAW) platforms. BAW devices utilize the entirety of the structural substrate, where an external PZT transducer couples compressional and shear acoustic waves into an etched fluid cavity (typically etched into monocrystalline silicon or borosilicate glass). Resonant standing wave modes form when the channel dimensions conform to integer multiples of the half-wavelength ($w = n \lambda / 2$). The fluid cavity acts as an acoustic waveguide, establishing internal pressure nodal planes perpendicular or parallel to the fluid transit axis.
Concurrently, surface acoustic wave devices employ single-crystal piezoelectric substrates—most notably $128^\circ Y\text{-cut } X\text{-propagating } \text{LiNbO}_3$—patterned with photolithographically fabricated interdigital transducers (IDTs). When driven at the resonant Rayleigh frequency, these metallic interdigital finger arrays produce localized, high-energy acoustic waves that propagate along the crystal surface, confining their mechanical displacement within one to two wavelengths of the interface.
When two counter-propagating surface acoustic waves interfere, they establish a standing surface acoustic wave (SSAW). As the Rayleigh wave encounters a fluid-loaded micro-channel, it leaks acoustic energy into the fluid at the Rayleigh angle ($\theta_R = \arcsin(c_0 / c_s)$, where $c_s$ is the substrate acoustic wave velocity and $c_0$ is the fluid acoustic wave velocity). This energy leakage couples the solid-state elastodynamic displacement directly into a periodic, highly localized three-dimensional pressure field, establishing ultrasonic Chladni figures that trap, sort, and organize micro-particles within continuous microfluidic laminar streams.
Mathematical Formalism & Physical Mechanics: Acoustic Contrast, Radiation Forces, and Plate Dispersion
Elastodynamics of Ultrasonic Thin Plates: Mindlin-Timoshenko Corrections
At the audio frequencies employed by Chladni, the flexural deformation of a thin plate of thickness $h$ is adequately modeled by the classical Kirchhoff-Love plate theory. In this limit, transverse normal lines remain planar and strictly normal to the mid-surface during deformation, neglecting both transverse shear strain and rotary inertia. The governing biharmonic equation for transverse displacement $w(x, y, t)$ is:
$$D \nabla_\perp^4 w + \rho h \frac{\partial^2 w}{\partial t^2} = q(x, y, t)$$
where $D = E h^3 / [12 (1 - \nu^2)]$ denotes the flexural rigidity, $E$ is Young’s modulus, $\nu$ is Poisson’s ratio, $\rho$ is the mass density of the substrate, $\nabla_\perp^4 = (\partial^2/\partial x^2 + \partial^2/\partial y^2)^2$ is the two-dimensional biharmonic differential operator, and $q(x, y, t)$ is the external transverse pressure load.
When transitioning to megahertz ultrasonic frequencies, the structural acoustic wavelength $\lambda_p$ becomes comparable to the plate thickness ($\lambda_p \sim h$). Under these physical conditions, the Kirchhoff-Love hypothesis breaks down: shear deformations throughout the cross-section become substantial, and rotary inertia alters the phase velocity of the flexural modes.
To determine the true modal line geometries of high-frequency ultrasonic Chladni plates, elastodynamic models must apply the Mindlin-Timoshenko plate theory. By incorporating a shear correction factor $\kappa^2$ (typically $\kappa^2 \approx \pi^2 / 12$ or $5/6$), the coupled equations of motion for transverse displacement $w$ and mid-surface normal rotations $\psi_x$ and $\psi_y$ become:
$$\kappa^2 G h \left( \nabla_\perp^2 w - \nabla_\perp \cdot \boldsymbol{\psi} \right) + q = \rho h \frac{\partial^2 w}{\partial t^2}$$
$$D \left[ \frac{1-\nu}{2} \nabla_\perp^2 \boldsymbol{\psi} + \frac{1+\nu}{2} \nabla_\perp (\nabla_\perp \cdot \boldsymbol{\psi}) \right] + \kappa^2 G h (\nabla_\perp w - \boldsymbol{\psi}) = \frac{\rho h^3}{12} \frac{\partial^2 \boldsymbol{\psi}}{\partial t^2}$$
where $G = E / [2(1+\nu)]$ is the shear modulus and $\boldsymbol{\psi} = (\psi_x, \psi_y)^T$. The dispersion relation derived from this formulation exhibits non-linear wave-number dependence at ultrasonic frequencies, revealing a significant phase velocity roll-off. This divergence dictates the layout of the megahertz vibration nodal lines, governing where acoustic radiation wells form on fluid-coupled substrates.
Low-Frequency / Kirchhoff Regime:
[Transverse Plane Normal Remains Fixed] ──> Phase Velocity: c_p ∝ √ω (Parabolic Dispersion)

Ultrasonic / Mindlin-Timoshenko Regime:
[Shear Strain & Rotary Inertia Included] ──> Phase Velocity: c_p asymptotic to Rayleigh/Shear limit
Derivation of the Gor’kov Acoustic Radiation Potential
For an acoustic field characterized by first-order acoustic pressure $p_1$ and first-order acoustic particle velocity $\mathbf{v}_1$ interacting with a spherical particle of radius $a$, density $\rho_p$, and compressibility $\kappa_p$ suspended in an inviscid fluid ($\rho_0, \kappa_0$), the time-averaged primary acoustic-radiation-force is governed by Gor’kov’s scalar potential formulation:
$$U_{\text{rad}} = V_0 \left[ \frac{f_1}{2 \rho_0 c_0^2} \langle p_1^2 \rangle - \frac{3 f_2}{4} \rho_0 \langle \mathbf{v}_1^2 \rangle \right]$$
where $V_0 = \frac{4}{3} \pi a^3$ is the particulate volume, and the angle brackets $\langle \dots \rangle$ denote a time-average over a full acoustic oscillation period $\tau = 2\pi/\omega$. The parameters $f_1$ and $f_2$ denote the acoustic monopole and dipole scattering coefficients, reflecting respectively the isotropic volume pulsation and the translational oscillation of the particle relative to the displaced host fluid:
$$f_1 = 1 - \frac{\kappa_p}{\kappa_0} = 1 - \frac{\rho_0 c_0^2}{\rho_p c_p^2}$$
$$f_2 = \frac{2 (\rho_p - \rho_0)}{2 \rho_p + \rho_0}$$
Applying the vector gradient operator yields the acoustic radiation force vector:
$$\mathbf{F}{\text{rad}} = -\nabla U{\text{rad}} = -V_0 \nabla \left[ \frac{f_1}{2 \rho_0 c_0^2} \langle p_1^2 \rangle - \frac{3 f_2}{4} \rho_0 \langle \mathbf{v}_1^2 \rangle \right]$$
In a canonical one-dimensional planar standing wave along the $x$-axis, defined by the pressure field $p_1(x, t) = p_0 \cos(k x) \cos(\omega t)$, Euler’s linear equation of motion provides the velocity field $\mathbf{v}_1(x, t) = -\frac{p_0}{\rho_0 c_0} \sin(k x) \sin(\omega t) \hat{\mathbf{x}}$. Substituting these into Gor’kov’s expression yields the classic spatial expression:
$$\mathbf{F}{\text{rad}}(x) = 4 \pi k a^3 E{\text{ac}} \Phi(\tilde{\kappa}, \tilde{\rho}) \sin(2 k x) \hat{\mathbf{x}}$$
where the acoustic energy density is $E_{\text{ac}} = \frac{p_0^2}{4 \rho_0 c_0^2}$, and the acoustic-contrast-factor $\Phi(\tilde{\kappa}, \tilde{\rho})$ is defined as:
$$\Phi(\tilde{\kappa}, \tilde{\rho}) = \frac{1}{3} f_1 + \frac{1}{2} f_2 = \frac{5 \rho_p - 2 \rho_0}{2(2 \rho_p + \rho_0)} - \frac{\kappa_p}{3 \kappa_0} = \frac{1}{6} \left[ \frac{5\tilde{\rho} - 2}{2\tilde{\rho} + 1} - \tilde{\kappa} \right]$$
When $\Phi > 0$, the acoustic radiation force vector points continuously toward the pressure nodes ($k x = (n + 1/2)\pi$), causing positive-contrast particles to migrate toward and immobilize along the ultrasonic nodal lines. Conversely, when $\Phi < 0$, the potential landscape inverts, dynamically expelling negative-contrast particles toward the pressure antinodes ($k x = n \pi$).
Acoustic Streaming Dissipation and Secondary Bjerknes Forces
The Gor’kov formulation assumes an idealized, non-viscous fluid continuum. In physical microfluidic chambers, real fluid media exhibit finite dynamic viscosity $\eta$ and bulk viscosity $\zeta$. Dissipation within the immediate hydrodynamic boundary layer yields viscous acoustic boundary-layer streaming (Schlichting streaming). The characteristic physical thickness of this oscillatory Stokes shear boundary layer is governed by:
$$\delta_v = \sqrt{\frac{2 \nu}{\omega}} = \sqrt{\frac{\eta}{\pi f \rho_0}}$$
For water at $f = 20,\text{MHz}$, $\delta_v \approx 126,\text{nm}$. Inside this boundary layer, large Reynolds stress gradients drive inner recirculating fluid vortices that leak steady momentum into the bulk fluid, generating macroscopic Rayleigh streaming vortex pairs. These hydrodynamic vortex currents exert a Stokes drag force on nearby particles:
$$\mathbf{F}{\text{drag}} = 6 \pi \eta a (\mathbf{u}{\text{stream}} - \mathbf{v}_p)$$
When particles are driven close to one another along the ultrasonic Chladni nodal lines, secondary inter-particle acoustic forces emerge. These interactions, known as secondary Bjerknes forces, arise because each insonified particle scatters acoustic waves, radiating a secondary spherical acoustic field that impinges on neighboring suspended matter. For two spherical particles of radii $a_1$ and $a_2$ separated by center-to-center distance $d$ (with $d \ll \lambda$), the time-averaged secondary Bjerknes force is:
$$\mathbf{F}_B(d) = 2 \pi \rho_0 a_1^3 a_2^3 \left[ \frac{\langle \mathbf{v}_1^2 \rangle}{d^4} \left( 3 \cos^2 \theta - 1 \right) \hat{\mathbf{r}} - \frac{k^2 \langle p_1^2 \rangle}{\rho_0^2 c_0^2 d^2} \hat{\mathbf{r}} \right]$$
where $\theta$ is the angle between the primary acoustic wave propagation vector and the inter-particle centerline vector $\hat{\mathbf{r}}$. At sub-micron distances, the $d^{-4}$ term dominates, generating strong inter-particle attractive potentials along the primary nodal lines. This secondary coupling drives dense colloidal self-assembly, aggregating dispersed suspensions into tightly organized close-packed crystallites along the ultrasonic Chladni figures.
Empirical Evidence & Observational Data: Precision Assembly and Bio-Fabrication
Colloidal Nanoparticle Patterning on Piezoelectric Resonators
Empirical investigations across 1 MHz to 40 MHz resonators confirm that sub-micron polystyrene beads ($a \sim 250,\text{nm}$ to $1,\mu\text{m}$) and dense silica nanoparticles ($a \sim 100,\text{nm}$) undergo rapid spatial focusing into stable geometric arrays within less than 500 milliseconds of RF power activation. Working on single-crystal lithium niobate substrates configured with crossed, orthogonal interdigital transducers, researchers project two-dimensional acoustic energy lattices directly onto the fluid-substrate interface.
Square Acoustic Node Lattice (2D SSAW):
     +       -       +       -
 + [ • ]   (   )   [ • ]   (   )   +
 - (   )   [ • ]   (   )   [ • ]   -
 + [ • ]   (   )   [ • ]   (   )   +
 - (   )   [ • ]   (   )   [ • ]   -

Legend:
 [ • ]  Pressure Nodes (Trapping sites for positive contrast: Φ > 0)
 (   )  Pressure Antinodes (Trapping sites for negative contrast: Φ < 0)
In these implementations, colloidal nanoparticle patterning occurs with high spatial fidelity. The particles collect at the Gor’kov potential minima, forming square, hexagonal, or linear stripes that trace the elastodynamic eigenmodes of the cavity. Quantitative particle-tracking velocimetry shows that the instantaneous particulate velocity scales linearly with acoustic power input ($P_{\text{RF}} \propto p_0^2$), matching theoretical Gor’kov force profiles until acoustic streaming velocities induce boundary-layer drag instabilities.
These platforms overcome the throughput limits of optical tweezers by manipulating hundreds of thousands of nanoparticle focal nodes concurrently across areas exceeding several square centimeters. A comprehensive breakdown of these solid-state acoustic interfaces appears in analyses of dielectric resonators and waveguides, which share the spatial boundary mathematics governing these elastodynamic systems.
Acoustic Bio-Fabrication Surfaces: Viable Cellular Matrix Alignment
The deployment of ultrasonic Chladni fields within tissue engineering has established specialized acoustic bio-fabrication surfaces. Because the applied mechanical forces distribute across the cellular volume without penetrating outer lipid membranes via disruptive electrical fields, acoustic pattern sorting operates in a biocompatible regime. Mammalian cell lines—including human neural stem cells (hNSCs), primary cardiomyocytes, and C2C12 skeletal myoblasts—have been aligned into anisotropic multi-cellular strands with post-exposure cell viability rates consistently exceeding 95%.
Suspension Reservoir (Random Heterogeneous Distribution)
  ├── Red Blood Cells (Positive Contrast: Φ > 0)
  ├── Monocytes & Lymphocytes (Positive Contrast: Φ > 0)
  └── Lipids / Free Triglycerides (Negative Contrast: Φ < 0)
                      │
                      ▼
[ High-Frequency Ultrasonic Standing Field (MHz) ]
  ├── Positive Contrast Stream ──> Focuses into Pressure Nodes (Nodal Lines)
  └── Negative Contrast Stream ──> Swept into Pressure Antinodes
                      │
                      ▼
Isolated Continuous-Flow Fractionation Outlets
During tissue scaffold generation, cells suspended in photopolymerizable hydrogels (such as gelatin methacryloyl, GelMA) are organized into oriented geometries via ultrasonic Chladni fields within 15 to 30 seconds. While the acoustic field maintains this aligned distribution, the matrix is stabilized through UV or blue-light photocrosslinking.
The resulting matrices exhibit high structural organization along the megahertz vibration nodal lines, promoting the anisotropic differentiation of myoblasts into multinucleated myotubes and guiding axonal outgrowth in aligned neural networks. This contact-free method avoids the shear-stress degradation, cytotoxic chemical labels, and cellular deformation characteristic of conventional microfluidic extrusion techniques.
Bulk Acoustic Wave (BAW) Resonators
- Operational Frequency Regime: Typically $500,\text{kHz}$ to $10,\text{MHz}$; limited by the thickness resonances of bulk transducer-substrate stacks.
- Particle Size Manipulation Limits: Highly effective for larger micro-particles ($5,\mu\text{m}$ to $100,\mu\text{m}$); loses resolution below $1,\mu\text{m}$ due to streaming vortex cross-talk.
- Fabrication Complexity: Low to moderate. Employs anisotropic wet etching of silicon, micro-milled glass, and mechanically clamped bulk PZT transducers.
- Acoustic Field Confinement: Three-dimensional acoustic resonance across the entire channel volume, generating full-depth planar nodal barriers.
- Biocompatibility: High acoustic power handling; exhibits substantial bulk thermal dissipation requiring external active Peltier cooling elements.
Surface Acoustic Wave (SAW) Devices
- Operational Frequency Regime: Typically $5,\text{MHz}$ to over $100,\text{MHz}$; defined lithographically by the interdigital transducer (IDT) finger pitch ($p = \lambda_{\text{SAW}}$).
- Particle Size Manipulation Limits: Highly effective for sub-micron colloidal particles ($100,\text{nm}$ to $5,\mu\text{m}$) and single-cell sorting.
- Fabrication Complexity: High. Requires cleanroom photolithography for metal lift-off deposition on single-crystal $\text{LiNbO}_3$ or quartz substrates.
- Acoustic Field Confinement: Localized near the fluid-substrate interface; leaky Rayleigh waves decay rapidly into the fluid depth.
- Biocompatibility: Operates at low power densities; minimizes thermal dissipation and cellular shear damage, facilitating direct live-cell sorting.
Multi-Frequency Switching and Reconfigurable Dynamic Cymatics
Static Chladni figures are limited by the immutable geometry of their boundary constraints: a given resonator geometry driven at an invariant resonant frequency $\omega_0$ yields a fixed modal configuration. Modern acoustofluidics circumvents this limitation by implementing dynamic multi-frequency switching, frequency chirping, and multi-channel phase modulation.
By altering the input RF driving signal over millisecond timescales, the corresponding Gor’kov potential wells are spatially translated across the substrate surface:
$$\Delta x = \frac{\Delta \phi}{2 k} = \frac{\lambda \Delta \phi}{4 \pi}$$
Modulating the phase difference $\Delta \phi$ between opposing interdigital transducers drives continuous, contact-free lateral transport of sorted particulate ensembles across adjacent microfluidic streams. Rapid switching between discrete higher-order eigenfrequencies shifts the megahertz vibration nodal lines dynamically, enabling user-defined micro-particle routing, dynamic colloidal concentration, and continuous cell fractionation within non-shearing flow environments.
Metaphysical Implications & Unified Synthesis: Cymatic Topography as Morphogenetic Template
Geometric Determinism: Acoustic Eigenmodes as Physical Morphogenetic Fields
The self-organization of matter along megahertz vibration nodal lines provides a physical foundation for concepts historically framed as “morphogenetic fields.” In 1938, Alexander Gurwitsch posited that embryonic cell differentiation and spatial morphology are guided by field geometries that direct cellular organization. While early twentieth-century biology struggled to identify a physical substrate for these fields—often sliding into vitalist speculation—modern acoustomechanics illustrates that harmonic wave-matter interactions provide an empirical mechanism for non-local, spatial patterning.
Harmonic Differential Operators (Helmholtz / Wave Equations)
               │
               ▼
   [ Boundary Conditions ]
               │
               ▼
Geometric Eigenvalues & Eigenmodes (Nodal Topographies)
               │
               ▼
[ Gor'kov Scalar Energy Wells ] ──> Dynamic Force (-∇U_rad)
               │
               ▼
Deterministic Spatial Patterning of Suspended Matter
The Gor’kov potential landscape $U_{\text{rad}}(\mathbf{r})$ acts as a physical morphogenetic template. Undifferentiated cellular matter responds directly to the mechanical forces exerted by acoustic energy landscapes. The physical boundary conditions of the acoustic resonator generate real-space geometric patterns, demonstrating that biological structuralization can be coordinated by harmonic wave states. This dynamic confirms that physical resonance alone can organize unpatterned, homogenous suspensions into ordered arrays, bridging the gap between historical cymatics and modern structural biology.
“Morphogenesis may be understood not as the localized consequence of chemical diffusion alone, but as a system of biophysical energy landscapes. Bioelectric gradients, elastodynamic fields, and acoustic-mechanical stresses establish spatial coordinate frameworks that instruct cells regarding their developmental trajectories.”
— Michael Levin, “Bioelectric Signaling: Reprogrammable Circuits Underlying Morphogenesis and Regeneration,” Cell, Vol. 184, No. 8, 2021, pp. 1971–1989.
“The structuralization of living matter requires mechanical energy inputs that guide morphogenetic movements. Physical resonance and dynamic tension fields determine the positions of cellular condensation, converting continuous boundary forces into discrete biological patterns.”
— Lev V. Beloussov, The Dynamic Architecture of a Developing Organism: An Approach to Morphogenetic Field Theory, Kluwer Academic Publishers, Dordrecht, 1998, pp. 112–134.
Scale Invariance of Resonance: Macro-Acoustics to Cellular Pattern Formation
The wave mechanics governing ultrasonic Chladni micro-sorting display fundamental scale invariance. The spatial distribution of matter along nodes of the Helmholtz operator,
$$(\nabla^2 + k^2) \psi = 0$$
is scale-independent, preserving its geometric features whether mapped at the millimeter scales of classical acoustics or the sub-micron dimensions of megahertz systems. The underlying mathematical structure—the projection of spatial boundary conditions onto an energetic spatial landscape—operates identically across disparate dimensional regimes.
This invariance reveals that the geometric organization of matter is an intrinsic property of physical resonance. Whether observing Chladni’s macroscopic sand plates, microfluidic SSAW colloidal lattices, or the larger architectural acoustics analyzed in cymatics history and modern acoustics, spatial organization emerges from the stationary interference nodes of standing waves. This mathematical continuity confirms that the formation of stable material geometries does not rely on random self-assembly, but is deterministically dictated by underlying eigenvalue boundary equations.
Dimensional Scale Invariance of Standing-Wave Eigenmodes:
[Macro Scale: λ ~ 10⁻¹ m]  ──> Chladni Plates (Sand on Brass)
[Meso Scale: λ ~ 10⁻³ m]   ──> Acoustic Levitation Chambers (Acoustic Wells)
[Micro Scale: λ ~ 10⁻⁶ m]  ──> SSAW / Ultrasonic Chladni Figures (Colloids & Cells)
[Nano Scale: λ ~ 10⁻⁹ m]   ──> Quantum / Plasmons (Local Density of States Nodes)
The Law of the Harmonic Field: Bridging Mechanical Waveforms and Living Matter
Ultrasonic Chladni mechanics demonstrate that mechanical waveforms can directly pattern living cellular matrices. By coupling the Gor’kov potential with high-frequency acoustic streaming, physical vibrational fields regulate cellular organization at the micron scale. The spatial nodes established by megahertz standing waves function as mechanical energy wells that guide living cells into organized architectures.
This biophysical mechanism illustrates how mechanical forces intersect with biological self-organization. As developed within the study of morphogenetic fields and cymatic templates, external physical fields can prescribe geometric order on responsive substrates.
Ultrasonic Chladni sorting demonstrates that non-linear acoustical systems are not merely diagnostic tools, but active, deterministic engines of spatial morphogenesis. By mapping harmonic wave fields into organized cellular structures, ultrasonic cymatics unites classical wave mechanics with modern biological fabrication.
Frequently Asked Questions: Advanced Technical and Biophysical Inquiries
Physical Resolution Boundaries and Brownian Motion Limitations
The absolute lower size limit for deterministic acoustic radiation sorting is governed by the physical balance between the primary acoustic radiation force $\mathbf{F}_{\text{rad}}$ and the stochastic kinetic collisions of thermal origin, quantified by the Péclet number ($Pe$):
$$Pe = \frac{|\mathbf{F}_{\text{rad}}| \cdot \Delta x}{k_B T}$$
where $k_B$ is the Boltzmann constant, $T$ is the absolute thermodynamic temperature, and $\Delta x \sim \lambda / 4$ represents the distance from an antinode to a node. Because the primary acoustic radiation force scales strictly with particulate volume ($|\mathbf{F}_{\text{rad}}| \propto a^3$), whereas the Stokes-Einstein Brownian diffusion coefficient scales inversely with radius ($D = k_B T / [6 \pi \eta a]$), decreasing the particle size causes thermal diffusion to rapidly overpower acoustic manipulation forces.
Energy Landscape Scaling:
F_rad  ∝ a³ · f · p₀²   ───► Dominates for a > 1 µm (Deterministic Trapping)
F_drag ∝ a               ───► Moderate influence (Acoustic Streaming Entrainment)
E_diff ∝ k_B · T         ───► Dominates for a < 50 nm (Brownian Dispersion)
In typical megahertz standing-wave fields (1 MHz to 10 MHz) with acoustic pressure amplitudes below 1 MPa, the functional lower particle-size limit for stable trapping is approximately $500,\text{nm}$. To manipulate smaller entities—such as exosomal vesicles ($a \sim 50\text{–}150,\text{nm}$) or metallic colloidal nanoparticles—the excitation frequency must scale into the ultra-high-frequency (UHF) regime ($f \ge 40,\text{MHz}$ to $100,\text{MHz}$). Scaling the frequency drives down the acoustic boundary layer thickness $\delta_v$ and scales the primary force linearly with $f$, raising the local Péclet number ($Pe \gg 1$) and suppressing thermal dispersion down to approximately 50 nanometers.
Thermal Dissipation and Cavitation Mitigation in Bio-Acoustics
Operating megahertz acoustic devices on living cellular suspensions requires managing two primary degradation modes: acoustic cavitation and thermal dissipation. Acoustic cavitation occurs when local peak negative pressures in the fluid surpass the Blake cavitation threshold, causing dissolved micro-gas bubbles to nucleate, expand, and collapse violently. These collapses generate localized shockwaves and hydroxyl free radicals that degrade biological membranes:
$$p_{\text{Blake}} \approx p_0 + \frac{2 \sigma}{R_0} \sqrt{\frac{2}{3} \frac{2 \sigma / R_0}{p_0 + 2 \sigma / R_0}}$$
where $\sigma$ is fluid surface tension and $R_0$ is ambient bubble radius. Because cavitation thresholds scale with frequency—requiring higher acoustic pressures to rupture fluids as megahertz frequencies suppress bubble nucleation times—cavitation is readily avoided by operating at moderate acoustic pressures ($p_0 < 1.5,\text{MPa}$) and high frequencies ($f > 5,\text{MHz}$).
Bio-Acoustics Preservation Envelope:
[ High Power / Continuous Wave (CW) ] ──> Acoustic Cavitation & Joule Heating (>42°C: Denaturation)
                    │
                    ▼
[ Pulsed RF Regimes (Duty Cycle 5-20%) ] ──> Preserves Integrity:
    ├── Peak Pressure Managed (< 1.5 MPa: Cavitation Suppressed)
    ├── Viscous Attenuation Dissipated (T maintained 37°C ± 0.5°C)
    └── Viability Retained (> 95%)
Thermal dissipation presents a parallel constraint. Viscous acoustic absorption within the fluid volume and mechanical losses inside the piezoelectric substrate generate internal Joule heating. If temperatures exceed $37^\circ\text{C}$ to $42^\circ\text{C}$, biological matter undergoes thermal shock and enzymatic denaturation.
Acoustic bio-fabrication systems manage these thermal effects by employing pulsed radiofrequency (RF) excitation modes (utilizing duty cycles between 5% and 20%) alongside active micro-machined Peltier heat sinks. Pulsing provides sufficient instantaneous acoustic radiation force to capture and organize the cells within milliseconds, while the off-cycles permit rapid thermal diffusion into the substrate, preserving physiological cell viability throughout extended sorting procedures.
Differentiation from Optical Tweezers and Dielectrophoretic Systems
Ultrasonic Chladni pattern sorting occupies a distinct performance regime relative to optical tweezers and dielectrophoretic (DEP) sorting architectures. Optical tweezers utilize focused laser beams to trap dielectric particles via photon momentum transfer. While optical tweezers achieve sub-nanometer spatial resolution and manipulate single macromolecules, they are constrained by low total throughput (handling one to ten particles concurrently) and induce localized photodamage and thermal stress when applied to living cells at high laser power densities ($I > 10^6,\text{W/cm}^2$).
Dielectrophoresis relies on non-uniform electric fields acting on the induced polarization of suspended matter ($\mathbf{F}_{\text{DEP}} \propto \text{Re}[K(\omega)] \nabla |\mathbf{E}|^2$). DEP manipulates cellular populations efficiently, but requires specialized micro-electrode arrays placed directly within the fluidic channel.
This direct contact exposes biological suspensions to electrochemical electrolysis, surface fouling, and substantial Joule heating when operating in highly conductive physiological buffers ($>1,\text{S/m}$). In contrast, ultrasonic Chladni sorting functions entirely non-invasively through acoustic pressure fields that operate independently of buffer ionic conductivity, preserving biological structure and processing up to hundreds of thousands of particles simultaneously.
Sorting Modality Trade-Off Matrix:
Modality:          Optical Tweezers        Dielectrophoresis (DEP)   Ultrasonic Chladni (SAW/BAW)
Throughput:        Very Low (1-10 cells)   Moderate (10³ cells/s)     High (>10⁵ cells/s)
Spatial Res.:      Sub-nanometer           Micron-scale              Micron / Sub-micron
Conductivity Sens: Insensitive             Critically Sensitive      Completely Insensitive
Damage Mechanism:  Photodamage / Bleaching Joule Heating / Lysis      Minimal (Cavitation-Suppressed)
Physical Basis:    Photon Momentum         Dipole-Field Gradient     Gor'kov Potential Gradient
Conclusion & Experimental Horizon
The formal integration of classical Chladni modal dynamics with the megahertz ultrasonic regime establishes a deterministic framework for non-contact micro-manipulation. By coupling Mindlin-Timoshenko elastodynamics with Gor’kov radiation potentials and controlled acoustic streaming, ultrasonic Chladni systems move beyond passive vibrational demonstrations to operate as versatile micro-sorting platforms. These high-frequency systems bridge classical mechanical wave physics with high-throughput bio-fabrication, providing label-free, biocompatible control over the architecture of microscopic and living matter. :::